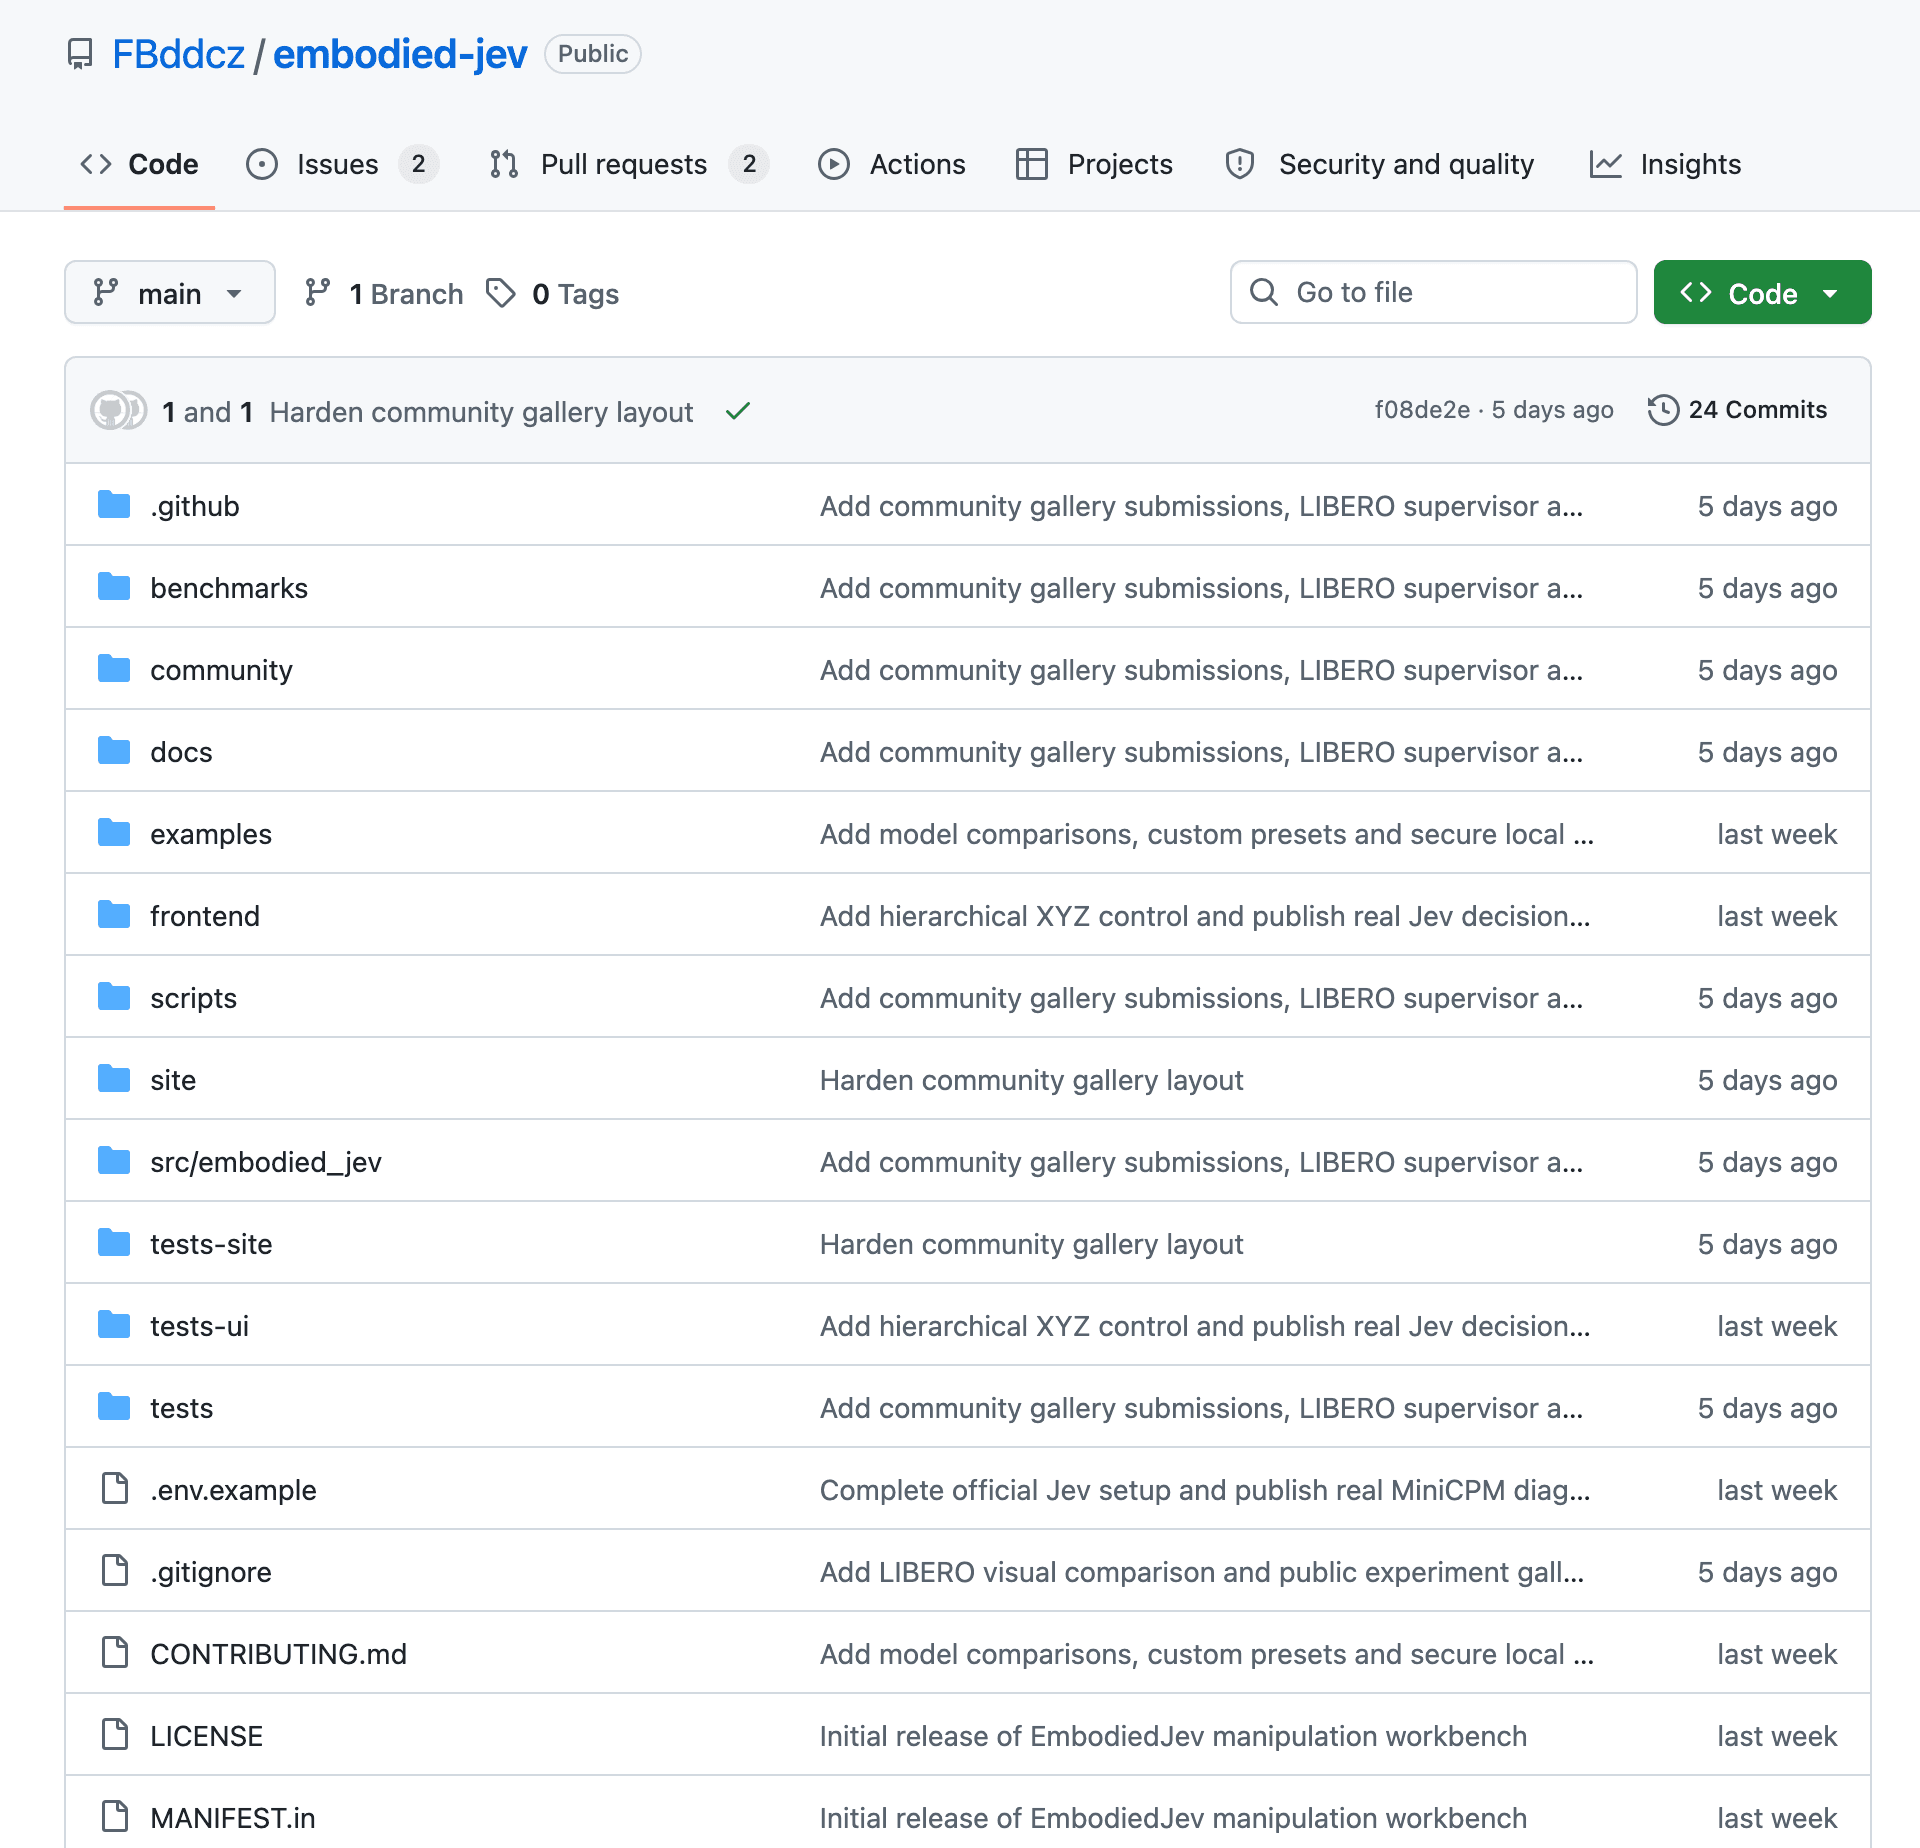
EmbodiedJev simulates a Franka Panda arm in MuJoCo with real physical contact, grasping, carrying and placing, and ships three tasks that run out of the box on a rule-based baseline with no API key, GPU or model weights needed.
A model slot in the interface plugs in TypeSafe Jev, Claude's native API, OpenAI-compatible APIs, or a local MiniCPM5-2B model, so the same observe-decide-act-feedback loop can be compared across them on speed and cost as well as outcome.
A live, no-install demo runs the recorded experiments and community-submitted reproductions in the browser, and the project accepts community write-ups of name, GitHub account, date, task, method and result.
What you get
- Full Python source code under the MIT license
- The MuJoCo simulation tasks, the model comparison workbench, and the live browser demo
 CodeRabbit participant
 Jev
 Python