
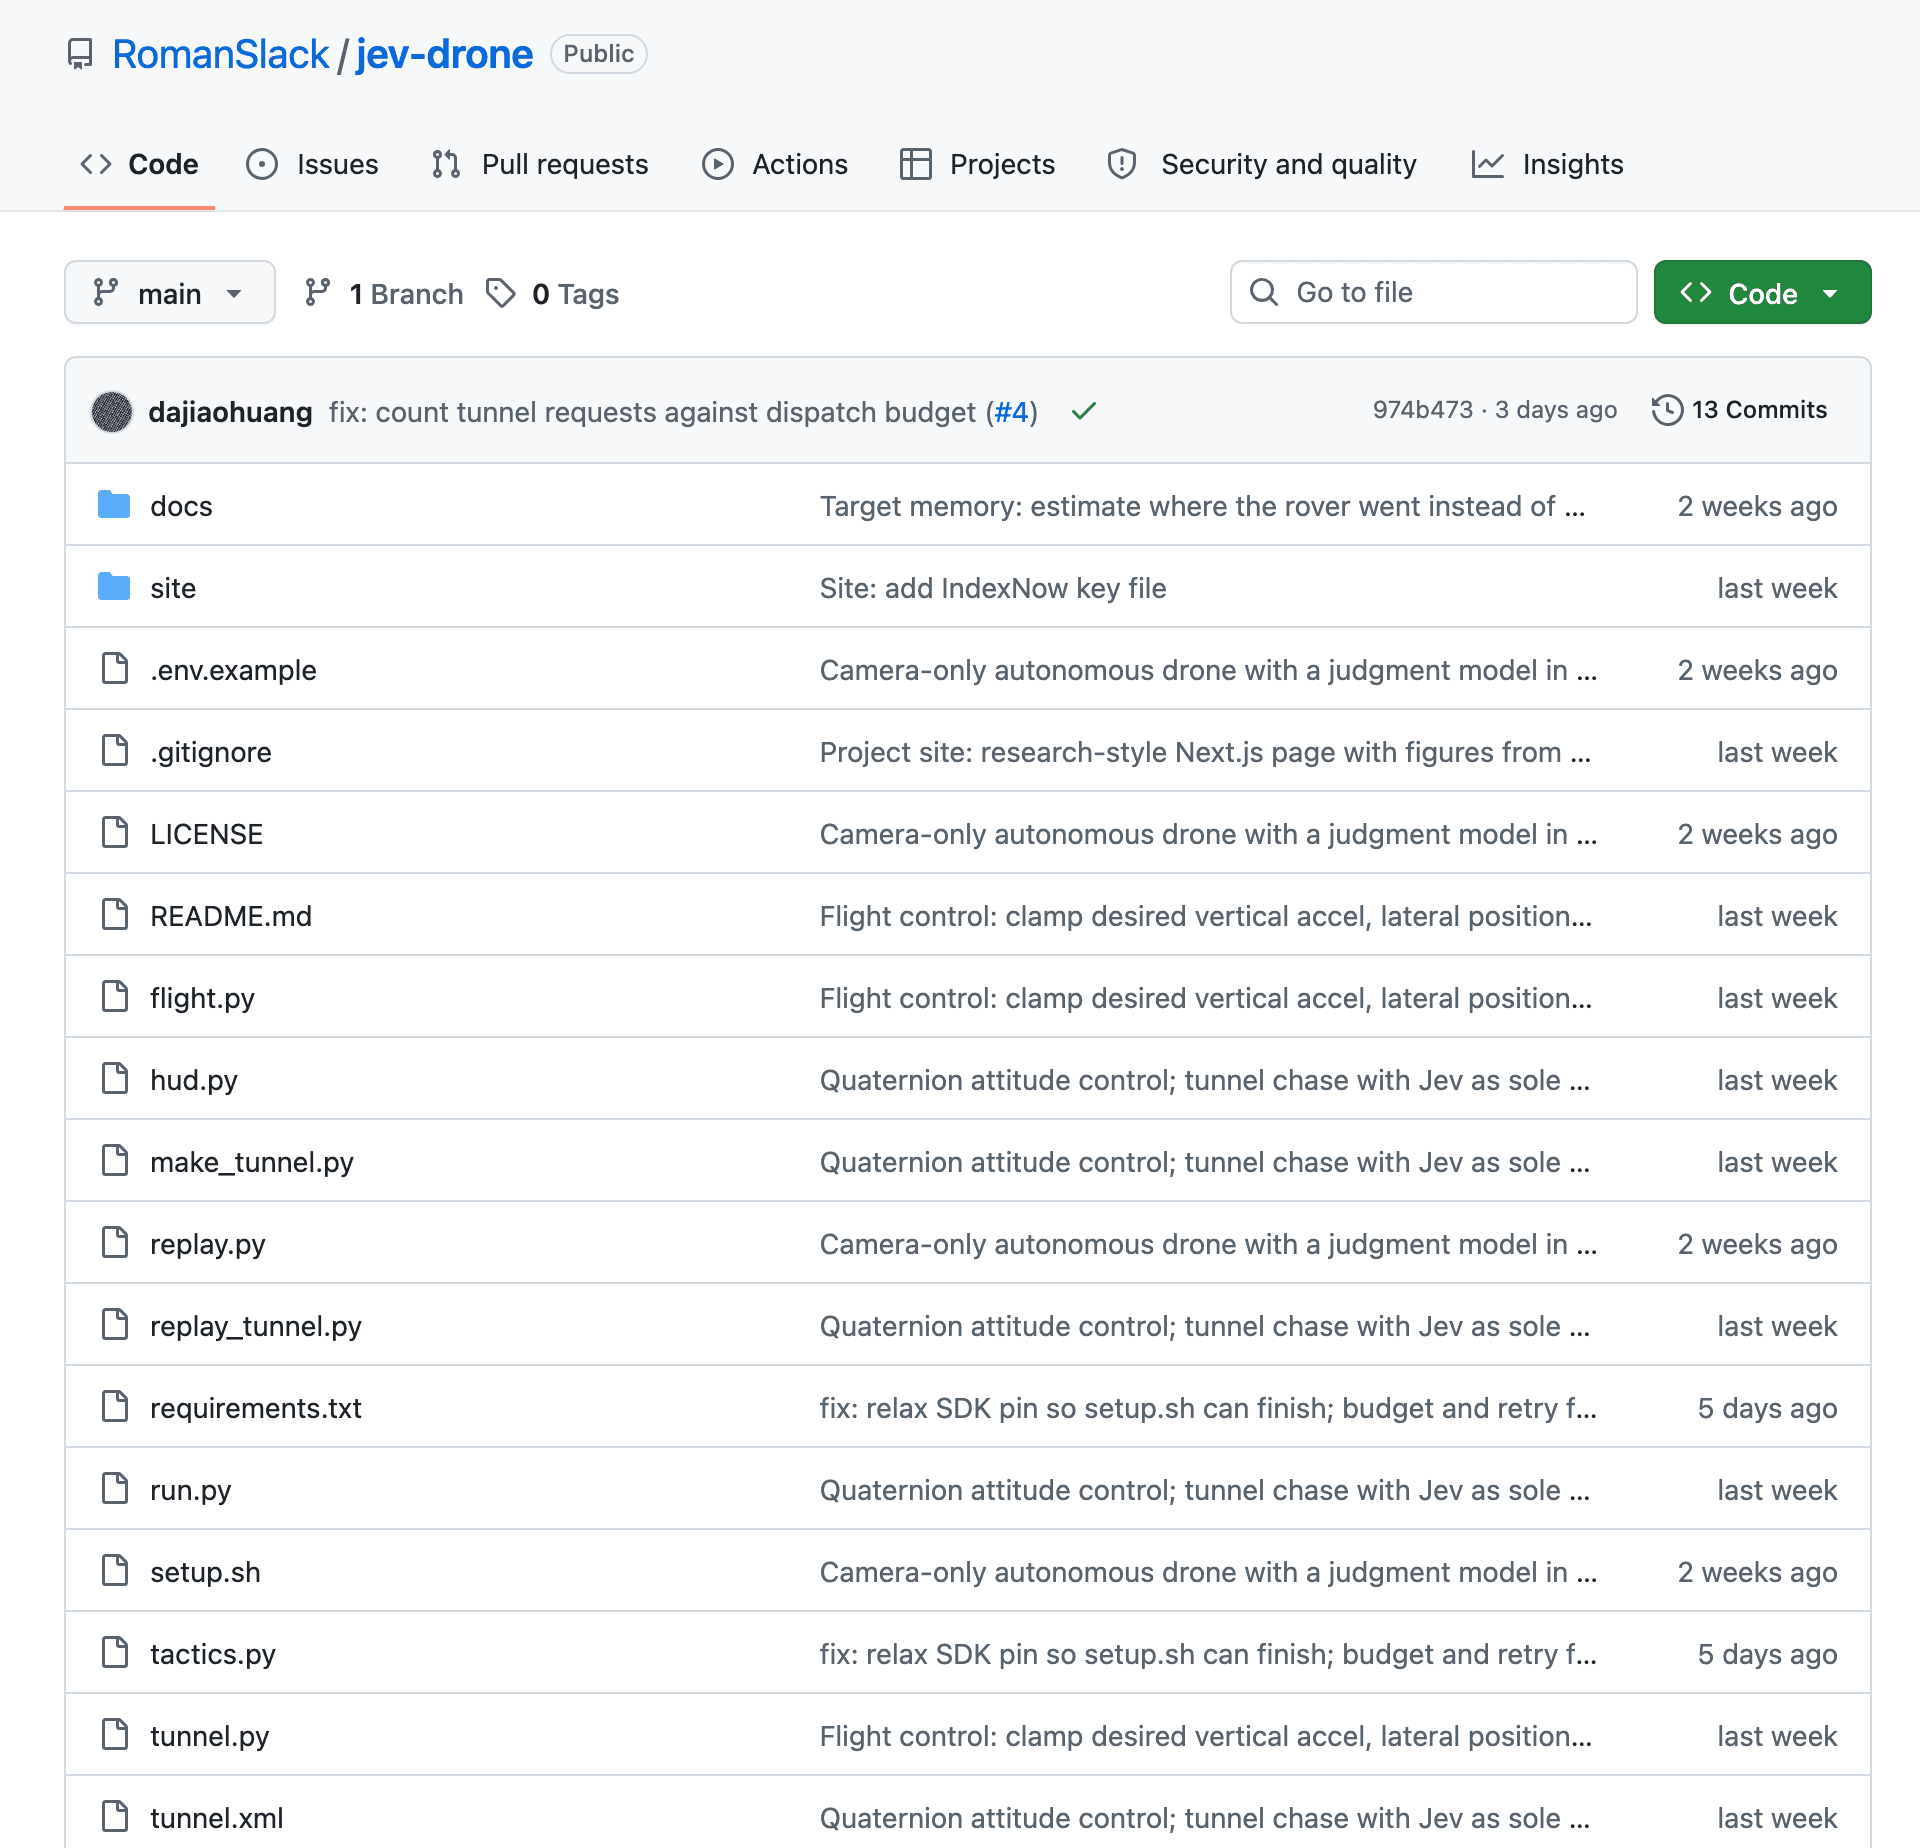
A quadcopter flies a five-station obstacle course in the MuJoCo physics simulator, with no scripted path and no waypoints, using only what its onboard camera sees.
About two and a half times a second, Jev looks at a description of the scene and decides what is going on: climb over, go around, or brake. Everything that has to happen fast, like keeping the drone stable, stays in ordinary code.
Written in Python, with a demo site to watch runs.
What you get
- Full Python source code, MIT licensed
- The MuJoCo obstacle course and flight code
 CodeRabbit participant
 Jev
 Python
 Vite


 JavaScript

 TypeScript
 React
 Node.js
 Fastify
 Vercel
 Anthropic


 Next.js
